Frontrunner

During my senior year of high school I was the captain of Design and Fabrication for Front Runner, competition robot for the 2024 FRC Crescendo season. The overarching strategy prioritized rapid cycle times, extreme reliability, and a low center of gravity. The final design used a swerve drivetrain, windows based vision processing, and several custom made subsystems shown below.



DRIVETRAIN & AUTONOMOUS PATHING
swerve modules with high power BLDC motors on a compact 26.5” square frame.
⅛” Aluminum tubing frame with rivets and tig welds, custom aluminum gussets allowed us to easily add on the subsystems after they were finished.
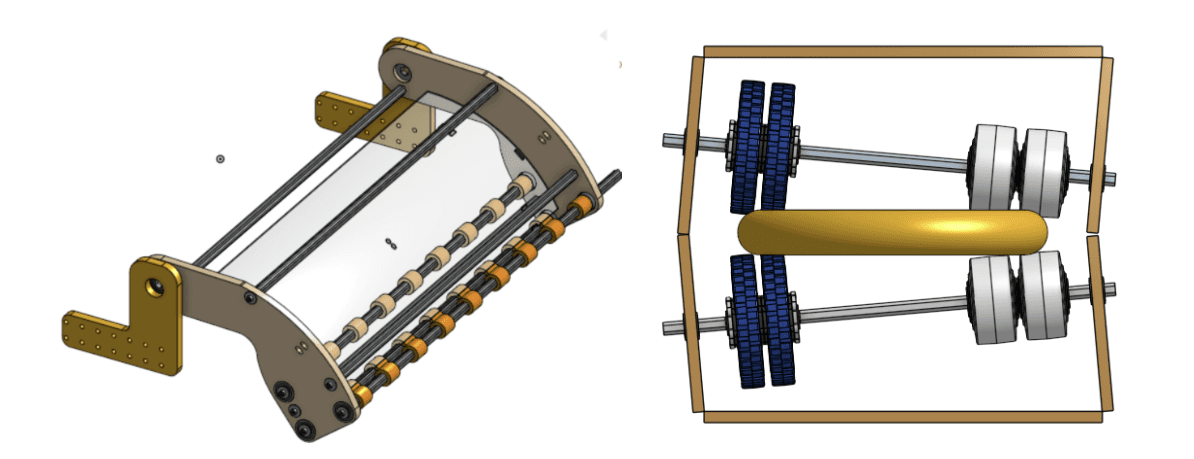
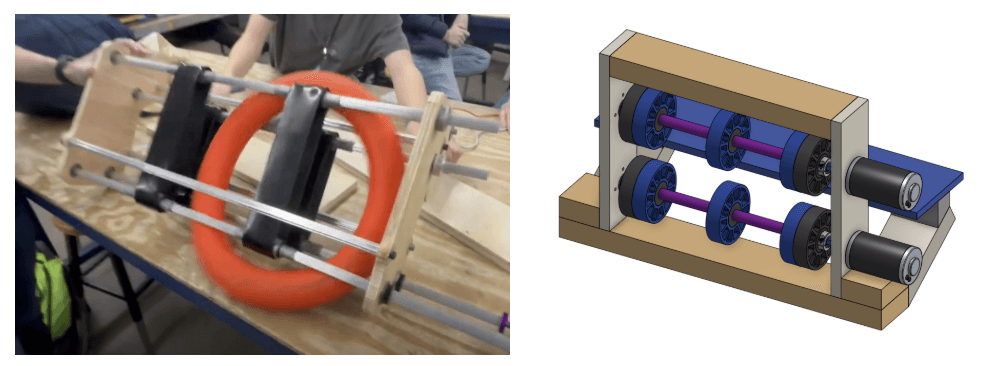
SHOOTER SYSTEM
Engineered a rigid 1/4-inch aluminum shooter structure with a 50:1 planetary and chain reduction with tensioner to minimize mechanical backlash and ensure consistent targeting.
Utilized two BLDC motors to independently drive the top and bottom rollers, allowing for vectoring of the game piece.
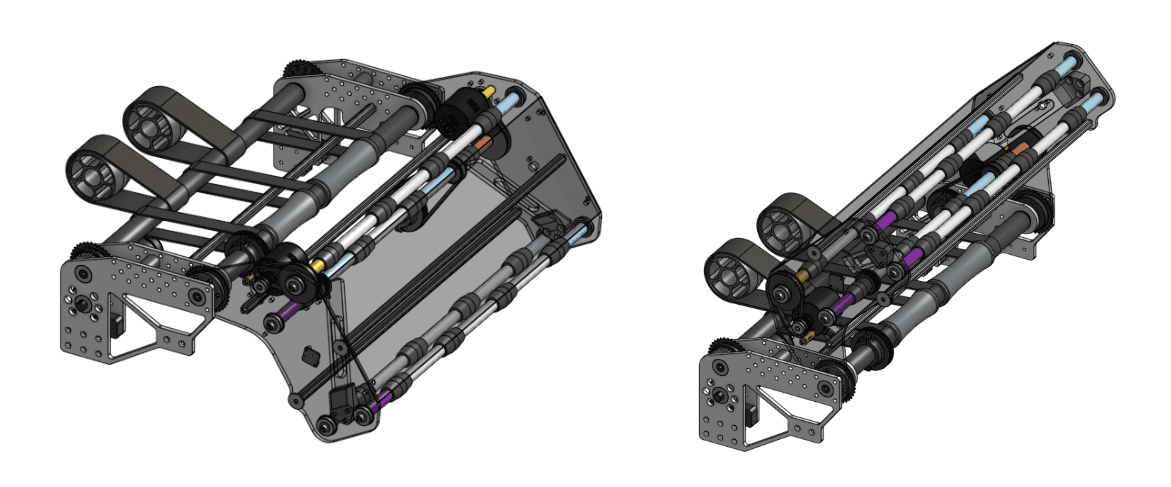
INTAKE & INDEXER MECHANICS
Impact resistant intake mechanism using ¼” polycarbonate arms and polyurethane belts driven by brushless motors.
Integrated a LaserCAN time of flight sensor to automatically detect game piece acquisition and halt intake motors.
CUSTOM CLIMBER & CAMERA RIG
Designed a fully custom climbing mechanism utilizing a CNC-machined 7075 aluminum core and 3D-printed polypropylene plungers to pull a 2,000-pound rated Dyneema cord.
Mounted a four-camera rig for 360 degree vision to estimate robot position on the field